

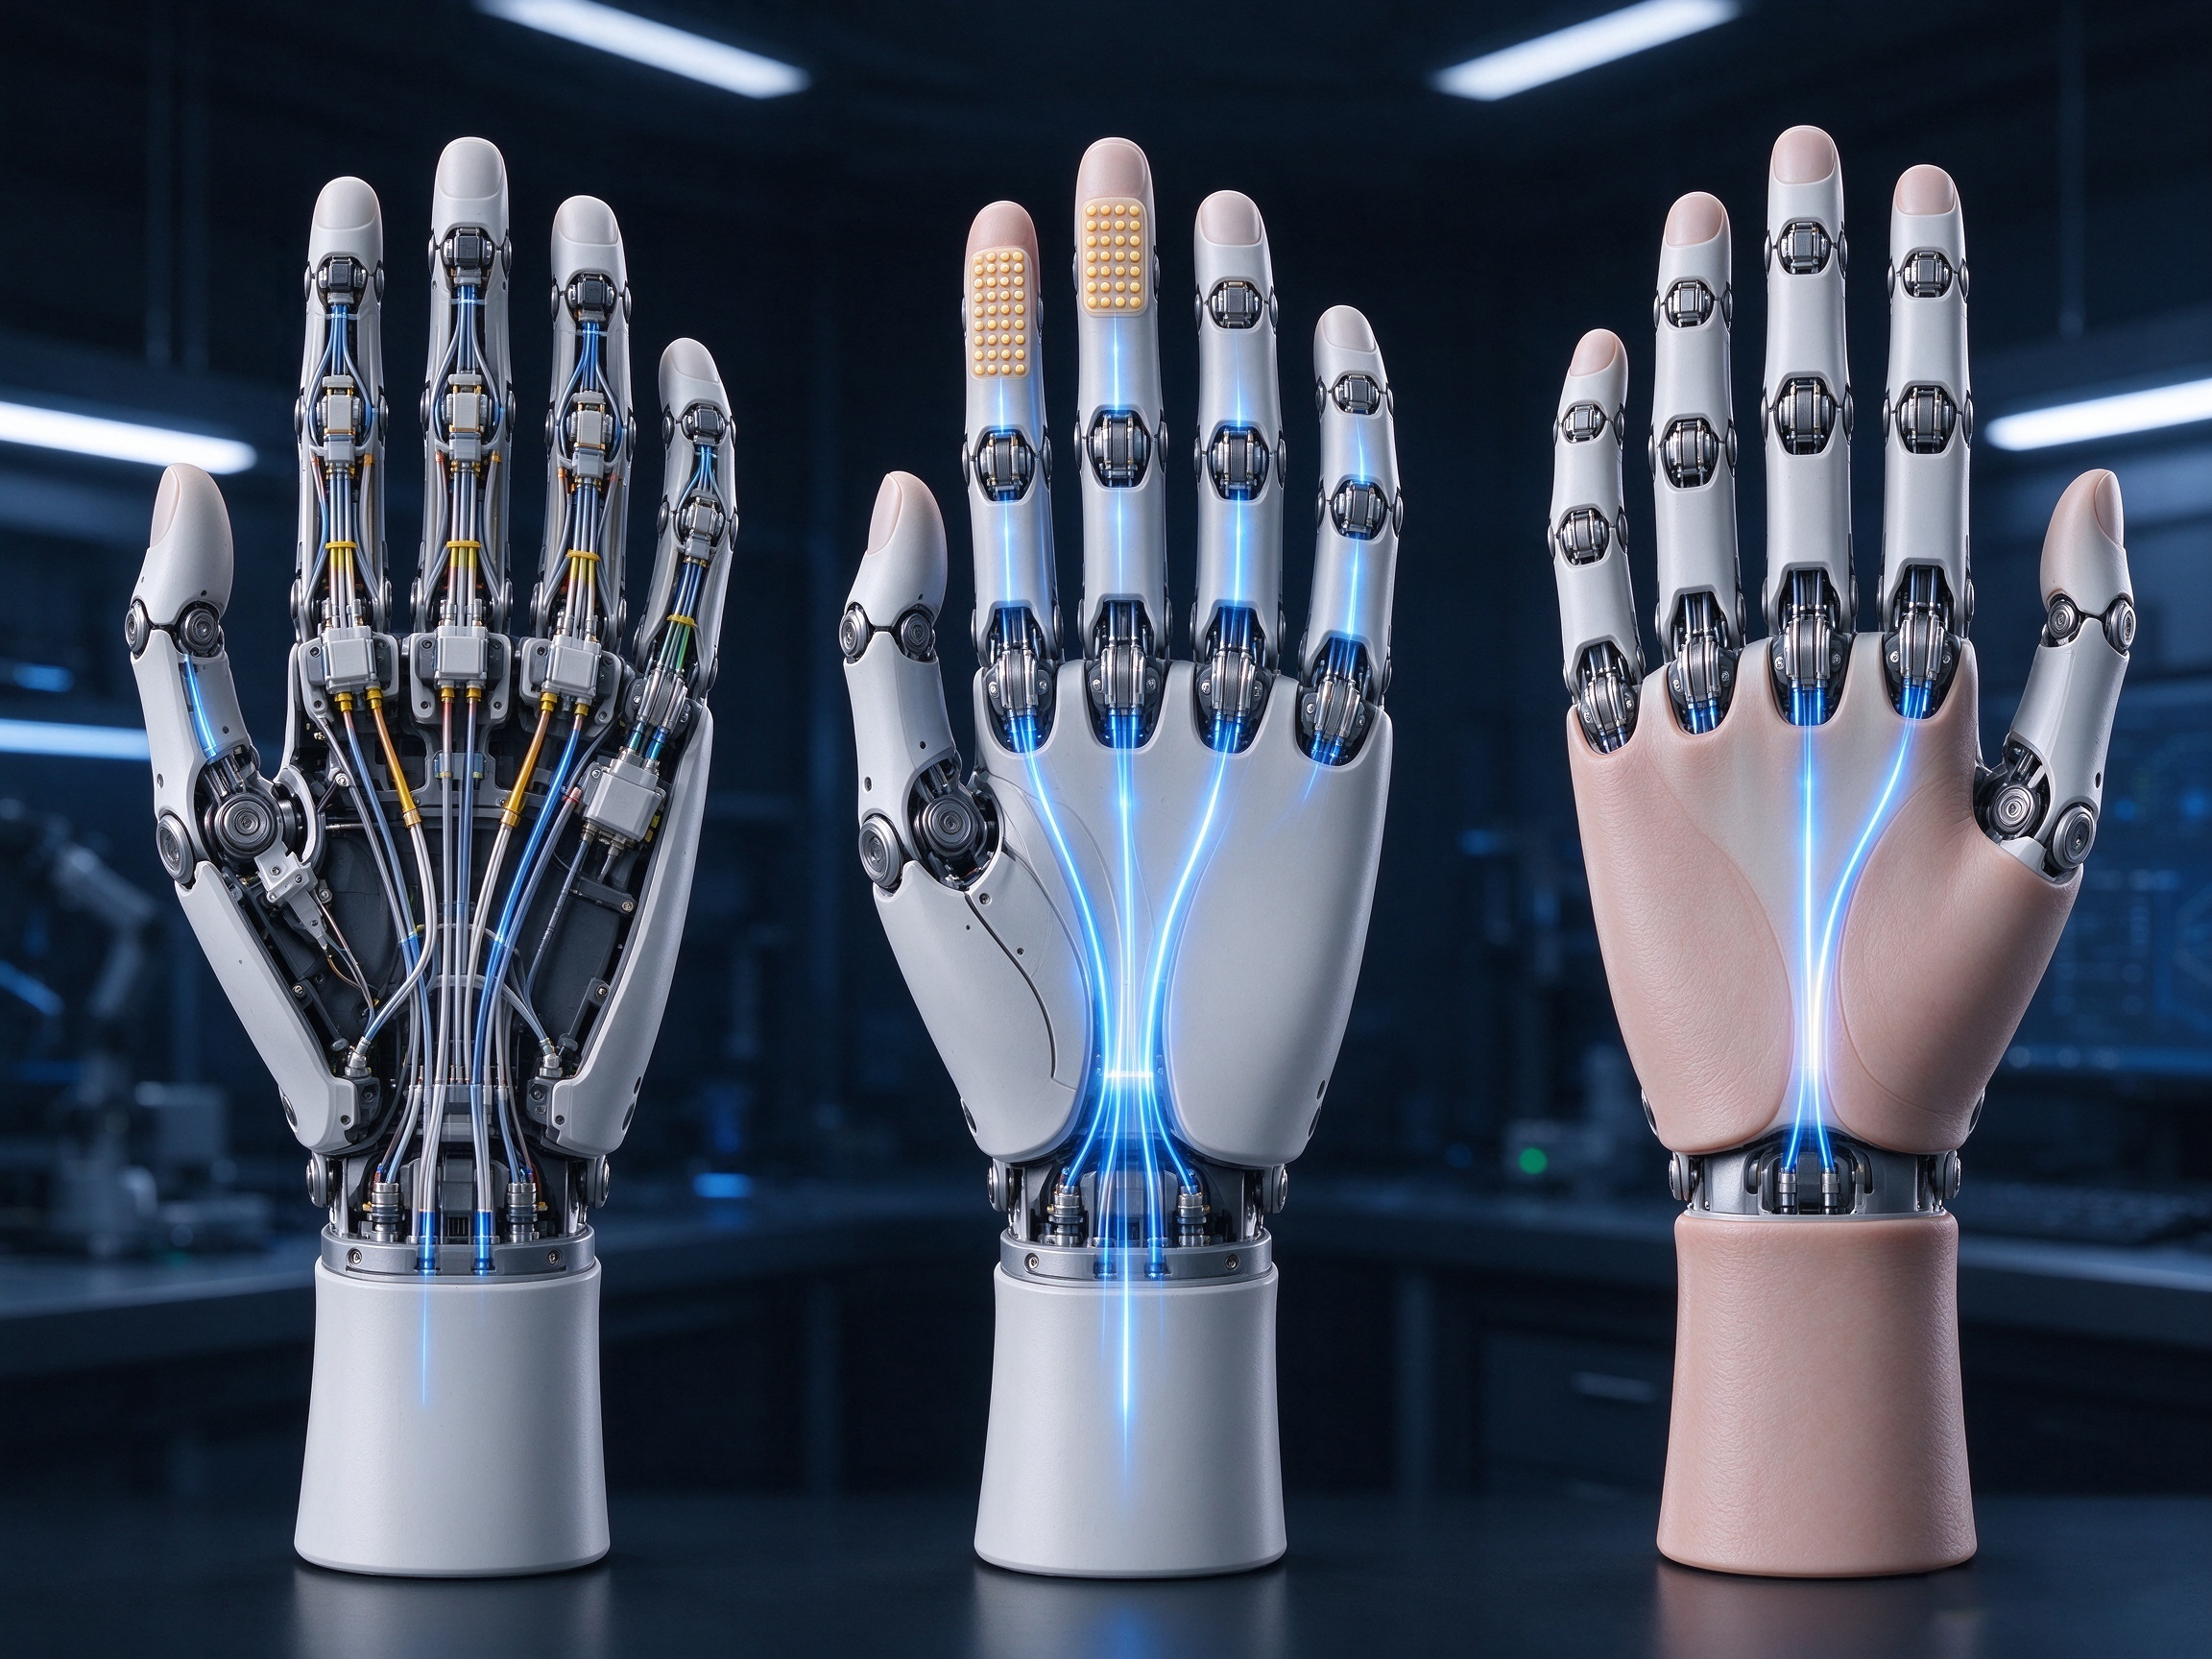
What Makes a Truly Bionic Dexterous Hand? Full-stack Technology from GZ LianyingPower
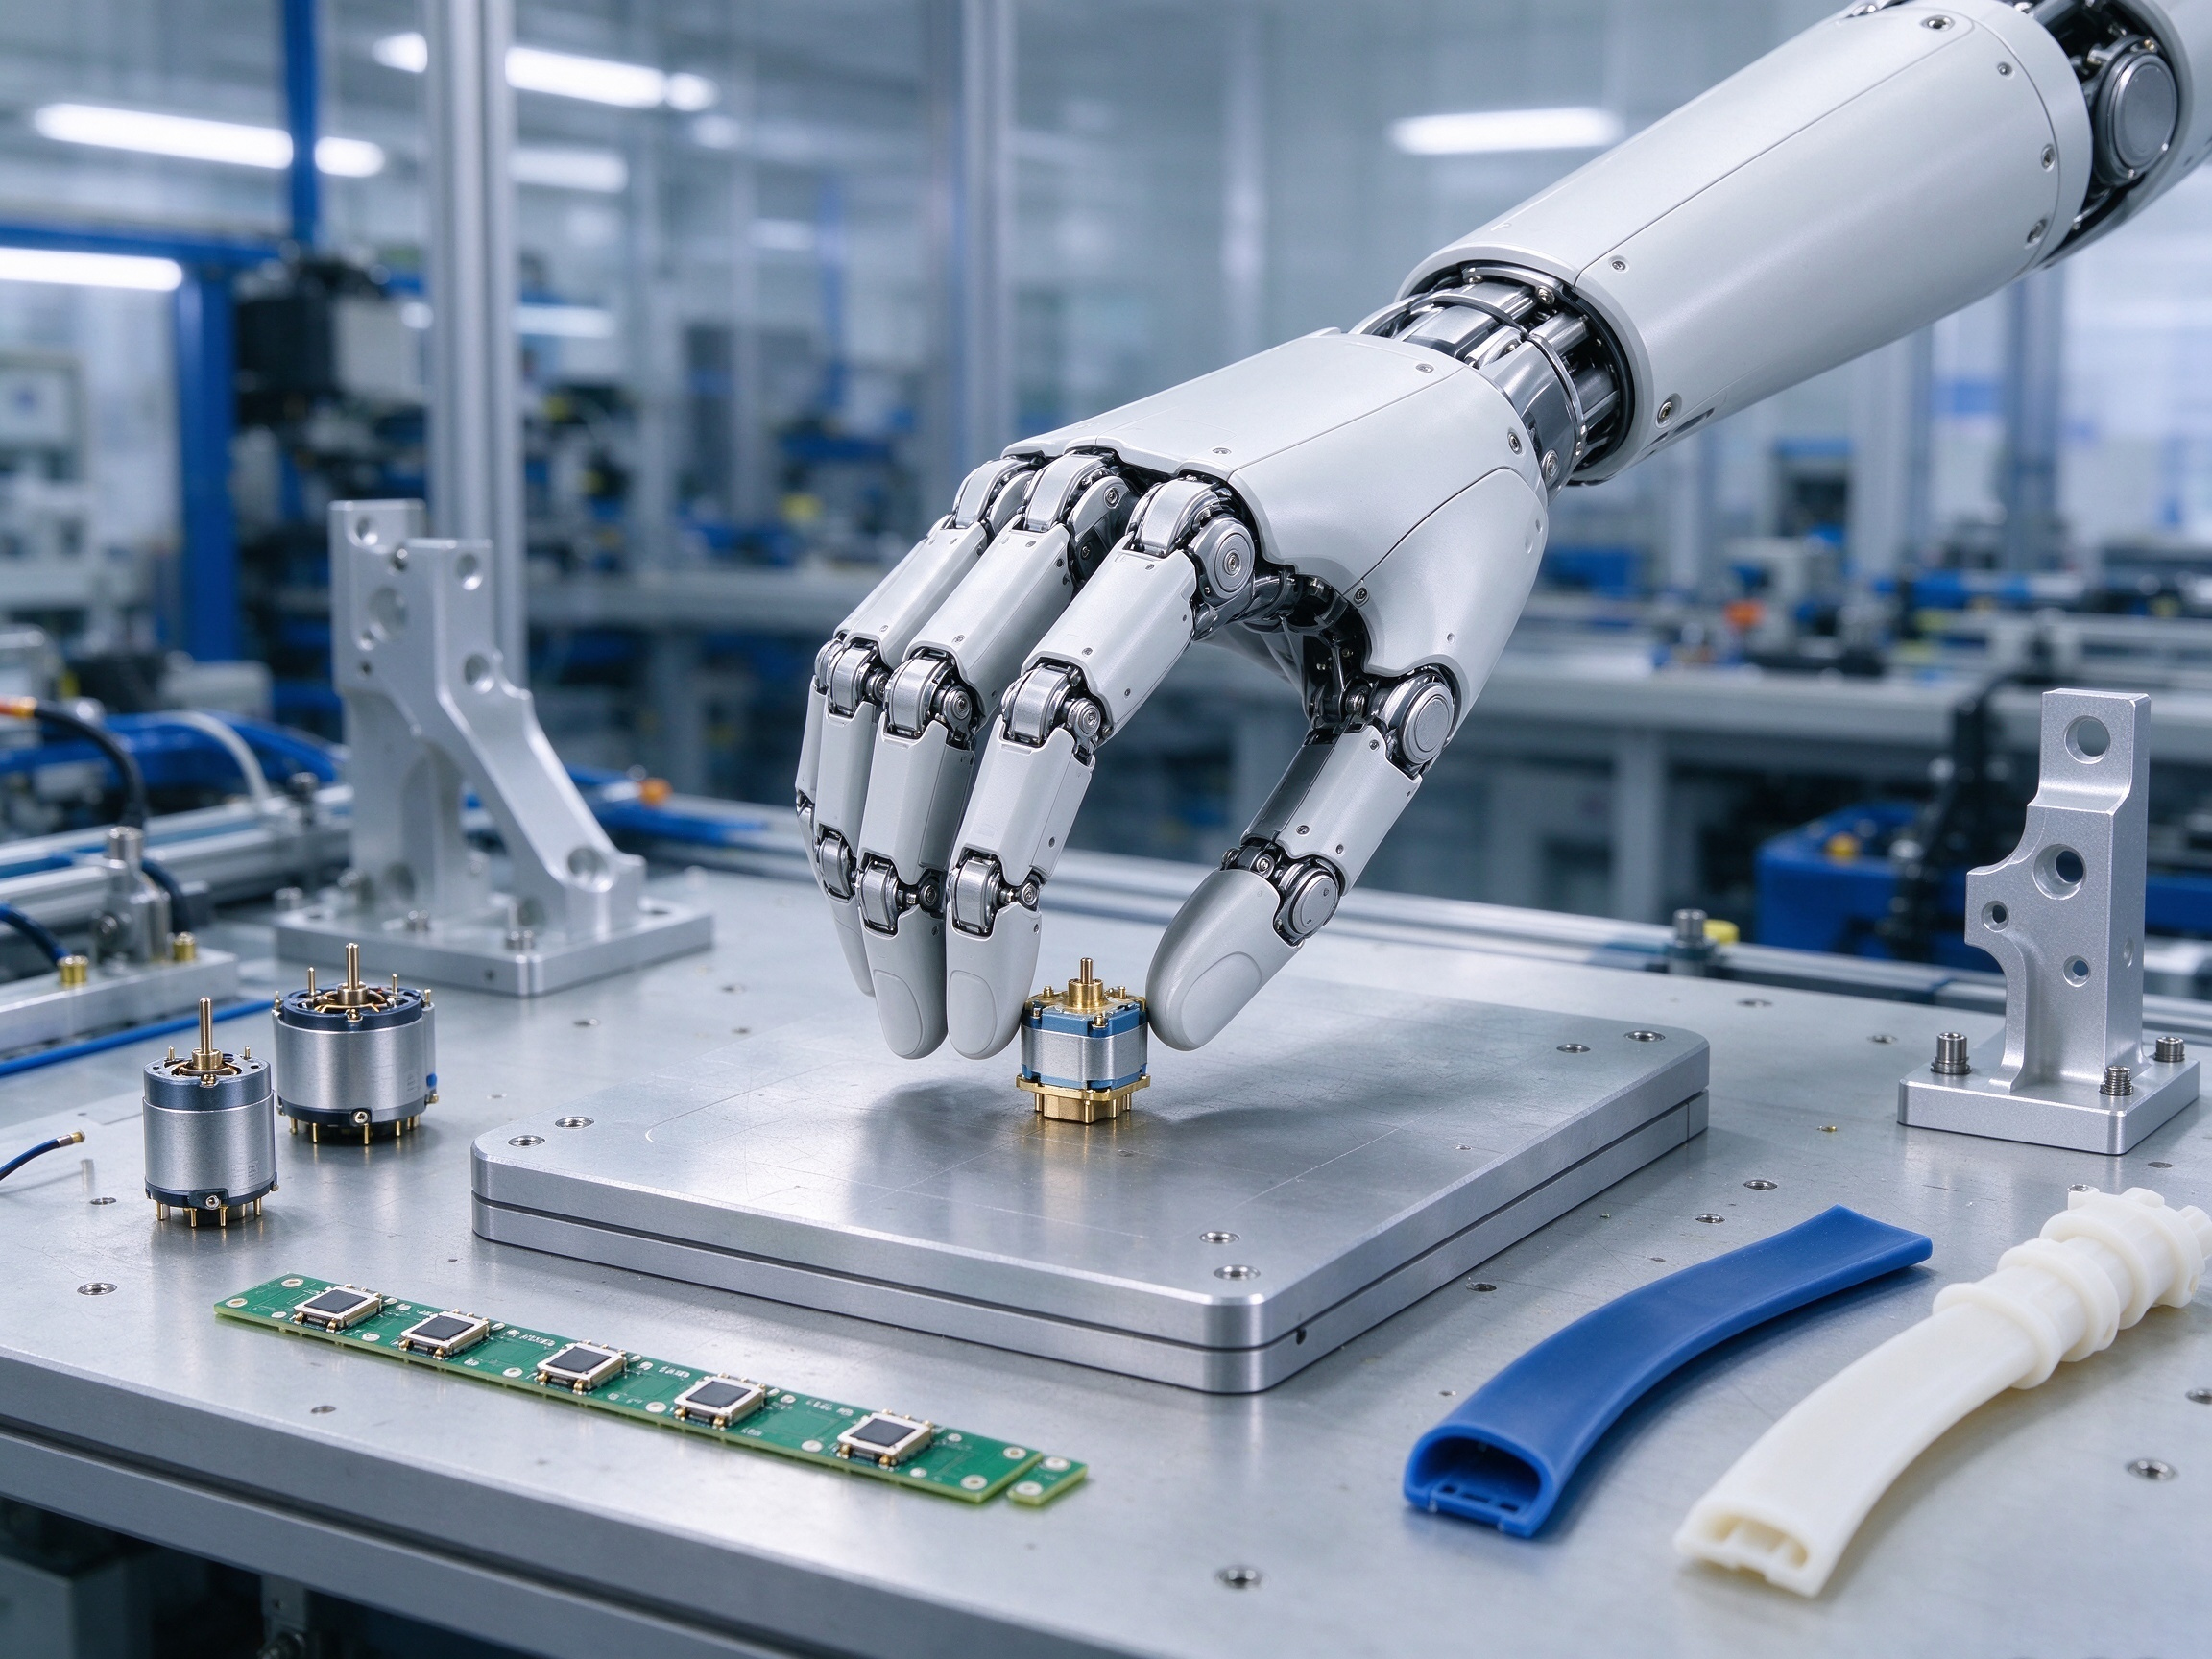
Humanoid robots will never achieve natural, human-like interaction without high-performance dexterous hands. Many robotic grippers on the market can only complete simple clamping tasks, while true bionic dexterous hands require the integration of structure, drive, sensing and control.
At GZ LianyingPower, we focus on the R&D and production of deep bionic dexterous hands and dexterous manipulation technologies. Our core innovation lies in the rigid-flexible-soft coupled design: rigid skeleton provides structural strength, flexible joints realize smooth rotation, and soft muscle-skin layers bring safe and compliant contact.
We have mastered a complete set of full-stack technologies for dexterous manipulation. This includes soft intelligent robotics, tactile-proprioceptive multi-modal sensing, brain-cerebellum-proprioception coordinated manipulation algorithms, lightweight high-stiffness topology optimization, and integrated system design covering thermal management, structure, actuation and sensing. Our advanced motion control and force control systems enable the hand to grip fragile objects, assemble small parts and adapt to uncertain environments.
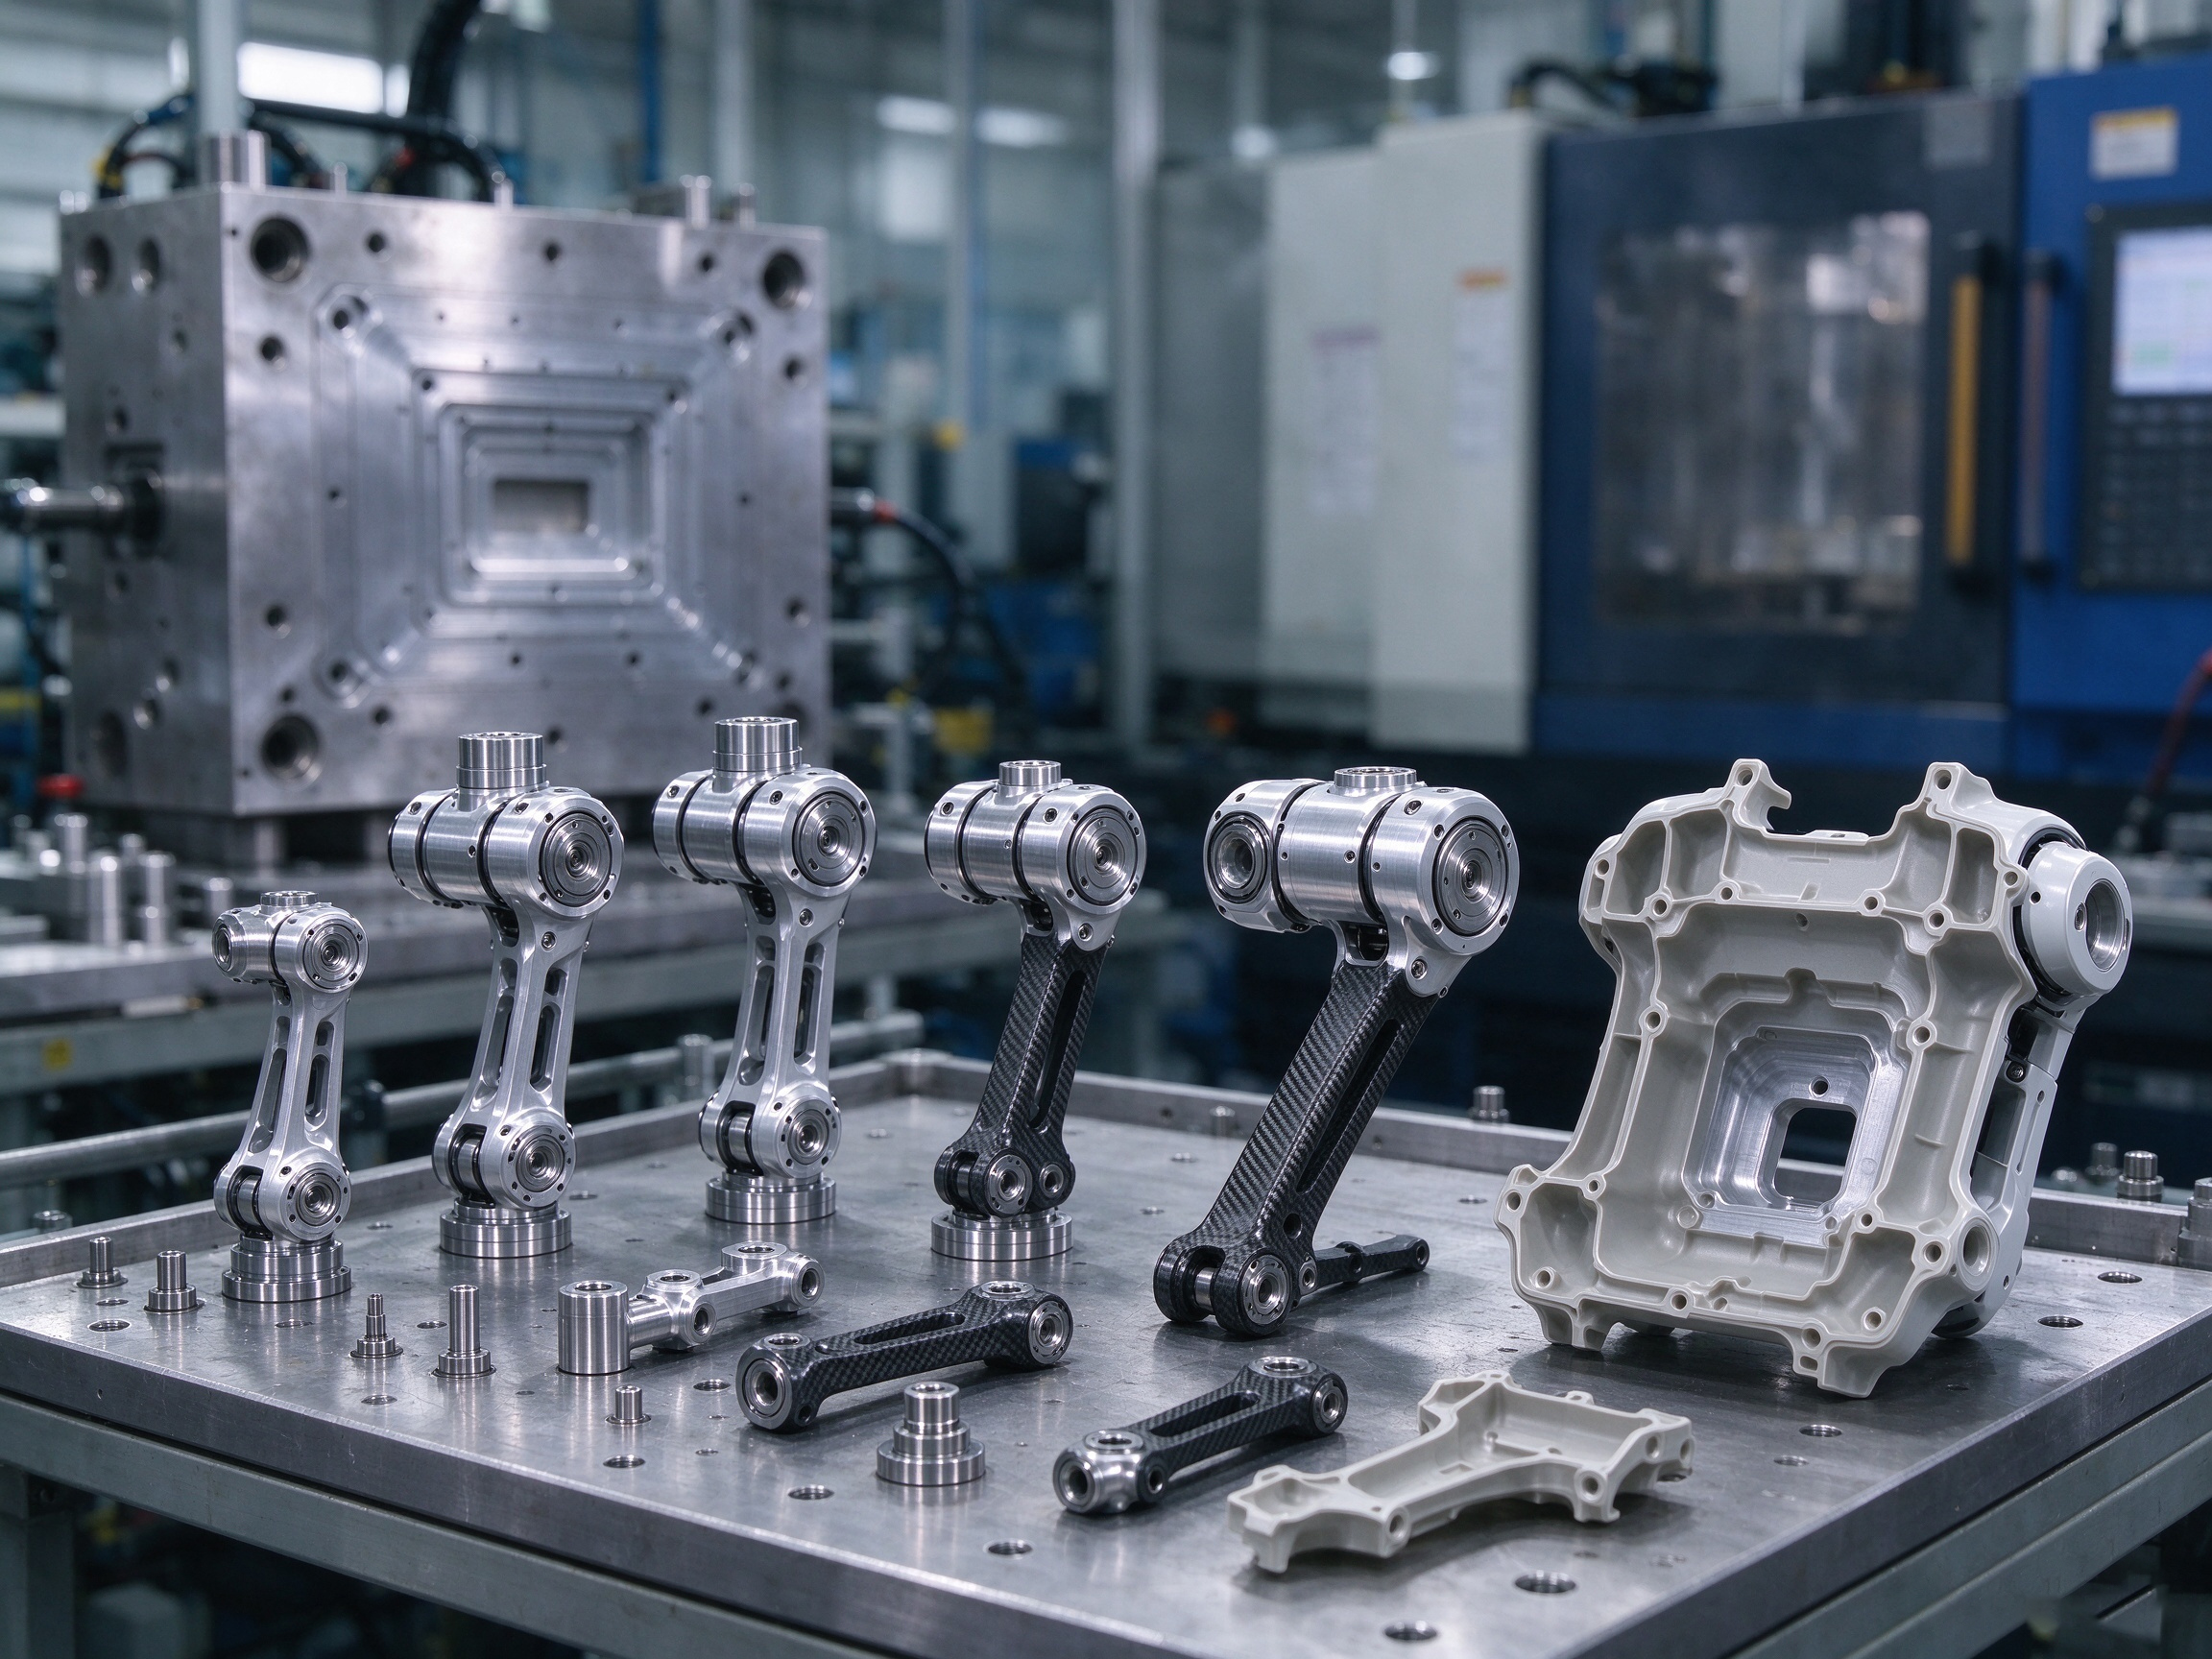
Our production bases in Shenzhen and Dongguan support rapid prototyping verification and stable mass production. We keep iterating hardware and control logic together, turning cutting-edge bionic robotics theory into deliverable products.
We welcome humanoid robot R&D teams, research institutions and robotics companies to discuss customized dexterous hand cooperation.
Tags: